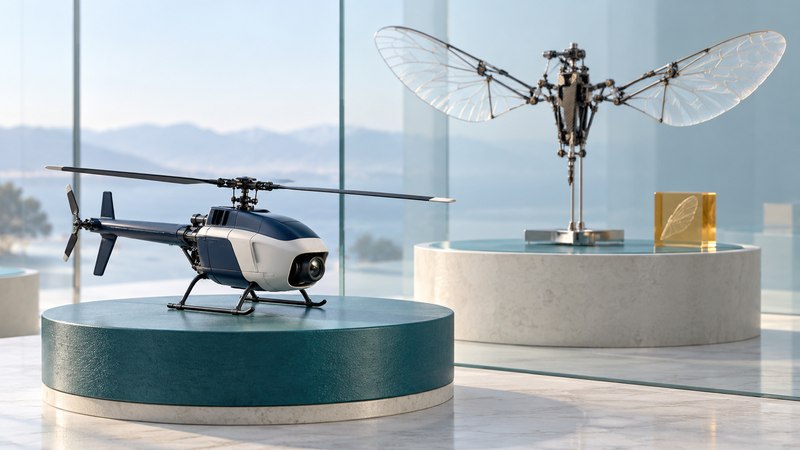
A tiny reconnaissance aircraft is a complete flying system: airframe, propulsion, power, sensors, control and communications. Shrinking one part changes what the others can do. Understanding those tradeoffs makes it easier to interpret a product specification or a striking laboratory video.
“Micro” and “nano” are used differently across research and product descriptions. Start with the actual dimensions, flight mass and configuration. A palm-sized helicopter and an insect-scale research robot can both be small while solving very different engineering problems.
Three designs, different compromises
| Design | What the arrangement enables | What deserves attention |
|---|---|---|
| Rotorcraft | Rotating blades provide lift, including while hovering. This includes small helicopters and multirotor aircraft. | Power in hover, rotor interactions, payload mass and control in disturbed air. |
| Fixed-wing aircraft | A wing produces lift as air flows over it during forward flight. | Launch and recovery space, flight speed and maneuvering room; hybrids add separate vertical-lift capability. |
| Flapping-wing research robots | Moving wings generate unsteady aerodynamic forces, often using insect-inspired structures. | Actuator efficiency, delicate mechanisms, onboard power and sensing, and the conditions used in the experiment. |
NASA’s compound-wing VTOL concept illustrates the design choice of combining vertical lift with efficient wing-borne flight. Hybrid arrangements add mechanisms and control demands. At any size, the configuration should be judged against the work it is intended to perform.
Detailed airflow matters too. NASA’s multirotor simulation work examines how rotor wakes interact and how changing their arrangement changes performance. A miniature aircraft’s behavior depends on its geometry and operating conditions, not simply its length.
Read the whole mass and power budget
A camera, radio or battery adds both capability and weight. More battery can carry more energy while also increasing the lift and structure needed to keep the aircraft aloft. Endurance therefore depends on the complete configuration and flight profile.
- Payload: establish what camera or other sensor was actually carried during a stated flight.
- Power: identify batteries, an external wire or an external energy source, and distinguish usable energy from peak power.
- Wind: ask whether a figure describes sustained wind or gusts, and which tested flight condition it covers.
- Navigation: identify which sensors estimate position and motion, and whether processing runs onboard or elsewhere.
- Communications: separate a radio-link distance from the distance and duration of a demonstrated flight.
- Useful sensing: check image quality, illumination, vibration, stabilization and delivery of the observations.
Separate a product specification from a research milestone
Black Hornet 4: read the manufacturer’s stated configuration
Teledyne FLIR’s Black Hornet 4 page describes a 70-gram aircraft with electro-optical and thermal imaging and a stated flight duration of more than 30 minutes. These are manufacturer statements, not results from a Yenra test. The same page lists a much larger total system weight, which includes equipment beyond the airborne vehicle.
This distinction matters whenever a headline says a system “weighs only” a certain amount. Compare aircraft mass with aircraft mass, and complete-system mass with complete-system mass. Check the current model and configuration before reusing any number.
RoboBee in 2019: untethered flight under laboratory illumination
The 2019 Nature paper’s abstract describes a four-wing integrated vehicle with photovoltaic cells and electronics weighing 259 milligrams. Harvard’s account of that experiment explains that the system used intense laboratory lighting and lacked onboard steering and control. It demonstrated an important power-and-lift milestone under those conditions.
RoboBee in 2025: a separate landing experiment
Harvard’s April 2025 report on RoboBee landing gear describes crane-fly-inspired legs and a revised controller for gentler landings. That experimental platform remained tethered to offboard control. Read the dates and configurations together: later research can isolate one problem using a tether even after an earlier experiment has demonstrated untethered flight.
Ask where the power, sensing and decisions live
| Description | What it establishes | Next question |
|---|---|---|
| Tethered | A physical connection remains during the experiment. | Does the connection carry power, commands or data, or act as a safety restraint? |
| Untethered | The reported flight removes the relevant physical tether. | How is energy supplied, and where is control performed? |
| Remotely piloted | A human supplies flight commands through a control link. | Which stabilization or navigation functions are automated? |
| Autonomous for a stated task | The system performs that specified task with defined human involvement. | Which sensors and computation enable it, and under what environmental limits? |
Automatic stabilization, following waypoints and choosing a route around unfamiliar obstacles are different tasks. Ask the source to specify the behavior it demonstrated. A robot’s appearance, small size or lack of a visible operator in a video supplies little evidence about its decision-making.
A five-question check for the next demonstration
- Which version? Record the model or paper, date, dimensions and complete flight configuration.
- What was onboard? Identify power, sensors, computation and the useful payload. Note external lighting, tracking or control equipment.
- What did it actually do? Separate liftoff, hovering, controlled flight, navigation and landing. Note duration and repeats.
- Where was it tested? Record laboratory or outdoor conditions, wind information, space constraints and any support apparatus.
- What is the status of the claim? Label a simulation, measured experiment, manufacturer specification or proposed future application accurately.
For example, a video showing a flapping robot lift off under laboratory lamps supports a claim about that flight. To assess a claim of autonomous outdoor inspection, look for an appropriate power source, onboard sensing and control, a useful payload and a demonstrated inspection task in representative conditions.
This approach gives advances their proper credit while making the next engineering question visible. Public research reports often state those remaining questions plainly.
Put the observations in context
Spy Satellites Explained applies the same distinction between a sensor measurement and an interpretation at orbital scale. For the historical setting of intelligence technology, explore spy-history museum trips or return to all Spying guides.